A paper-thin robot swims using living muscle cells: how MIT engineers got it to obey light
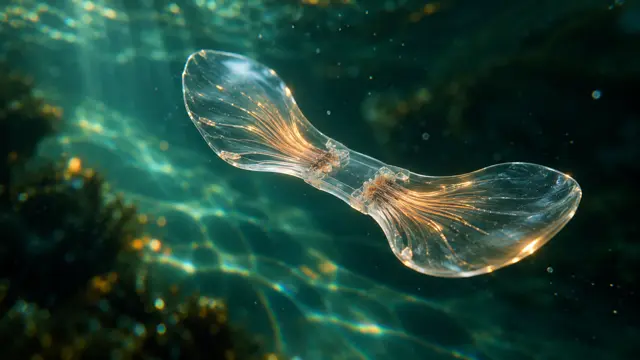
Short answer: according to MIT News, engineers at the Massachusetts Institute of Technology, led by associate professor Ritu Raman, built a swimming robot as thin as a sheet of paper. Its "skeleton," about the size of a stick of gum, is made from a film of gel, and its two "fins" are covered with a layer of living muscle cells thinner than a single strand of hair, genetically engineered to twitch in response to light. Flashing light on one fin or the other controls the direction and speed: the robot showed it can swim and turn through a simple water maze. It's the first robot this thin and flat, muscle-powered and capable of locomotion, and the result is part of the lab's broader work on "biohybrid" robots built from living tissue.
How the robot works and what the test showed
When the researchers shine light on one fin, the muscles on its surface twitch in response, and the whole fin flaps with enough force to pull the robot through the water. By flashing light on one fin or the other, at different moments, they can control the swimming robot's direction and speed. At its fastest, the robot covers about four times its own body length in a minute: according to MIT News, that's a "snail's pace" compared to Olympic swimmers, who can cover up to 65 body lengths a minute, but it's comparable to more leisurely swimmers like the cow shark (a species with no established Russian common name; literally, "cow shark"), which keeps roughly the same pace. Ritu Raman commented: "It takes a lot of force to move through water versus air. The robot's quite strong, given its size."
According to Raman, the biohybrid robots currently built in her lab and others are usually assembled from bulky, three-dimensional chunks of lab-grown muscle tissue that require millions of cells to make. A thinner, lighter design like this robot, she says, could turn out to be cheaper to build and move more efficiently. Raman also connects such robots to a longer-term goal: in her words, robots powered by living muscle tissue could one day perform delicate work, like exploring environments too fragile or unpredictable for conventional hardware, because living tissue is soft, responds to its surroundings, and can heal itself. That's the researchers' speculation about a future application, not a description of an already-working technology.
How the team chose a material to make the muscles pull harder
A year earlier, the same Raman group had already made a similar disk of artificial muscle tissue modeled on the iris of the eye: muscle cells deposited onto a gel with a pattern of grooves moved, under light, so that the disk stretched and contracted the way an iris widens and narrows the pupil. That was the first demonstration that muscle cells could be grown in a thin layer in a complex pattern with controllable movement in different directions, but according to Raman, the movements themselves were minuscule, around 100 microns: "From a robotics perspective, their movements were insignificant."
In the new work, the team aimed to get noticeably more force out of the muscles, enough to move a swimming robot. The key turned out not to be the muscle cell itself, but the "skeleton" it grows on. In the earlier design, the cells were grown on fibrin, a very soft gel that the team realized quickly shrivels under the force the muscles generate. So the researchers tuned three properties of the gel: its composition, its stiffness, and the shape of the grooves stamped into its surface. They tried several groove shapes and found that on gels with square grooves, the muscle cells aligned more evenly than on curved ones, and more evenly aligned cells tend to fuse into fibers and form a stronger, more coordinated tissue. Instead of fibrin, the team used gelatin methacrylate (GelMA), a material often used in tissue engineering, and tried several formulations of different stiffness: the cells grew more aligned and generated more force specifically on stiffer gels. They also fine-tuned the thickness: a half-millimeter-thin film of GelMA offered good support for a single layer of muscle cells and was light enough that the cells didn't peel away from the gel when they contracted. Finally, the team "exercised" the muscles with repeated flashes of light to strengthen them.
With the material and cells settled, the team assembled a thin, two-finned robot: gel stamped with square grooves on both sides, covered with muscle cells that fused into fibers and formed a strong, aligned tissue. According to Raman, you can think of the robot as having two independent muscles: shine light on just one, and only that one moves; shine on both, and both flap. The robot was submerged in a large petri dish of water, with a light source manually maneuvered above it, and it followed the light, moving through a maze the team had placed in the dish.
What's next
The robot's current design, according to MIT News, is fairly basic: the researchers first wanted to show it could generate enough force to swim at all. The next goal, according to Raman, is to optimize the body design for faster swimming. But even at its current slow speed, she says one could imagine using such a muscle-powered swimmer for things like environmental monitoring in aquatic environments. The research was supported in part by the US Office of Naval Research; the source describes this as naming one of the funding sources, not a military application of the robot itself.
When this doesn't apply to you
If bioengineering and soft robotics aren't your area, this story offers no advice for business or technology; it's purely a science piece. You can check it yourself against the original MIT News article (link in "Sources"): it describes the actual experiment, which is the result that was shown. The robot was submerged in a petri dish of water, while researchers manually moved a light source above it that guided it through a maze. Keep that separate from Raman's comments about a future application of such robots for environmental monitoring: that's the researchers' speculation about a possibility, not something the experiment itself demonstrated.
Bottom line
MIT engineers built a paper-thin swimming robot that moves using living muscle cells that respond to flashes of light, and showed it can navigate a simple water maze. The key turned out not to be the choice of cells themselves, but the material and shape of the "skeleton" they grow on: a stiffer gel with square grooves let the cells align more evenly and generate more force. Its speed is still modest, around four body lengths a minute, and the researchers call the robot's current form fairly basic; the next goal is to make it swim faster.
I run a portfolio of AI agent and automation projects for business: see examples or reach out directly about your own task.
Sources
- Jennifer Chu. Powered by muscle cells, paper-thin robot swims through watery maze. MIT News, September 29, 2026. https://news.mit.edu/2026/powered-by-muscle-cells-paper-thin-robot-swims-through-watery-maze-0929